SimDuoReal
Single object-centric bimanual policy for diverse tasks with emergent dexterity
Tech ReportInteractive Demo ↗Coming soon
 ROBOT LEARNING
Learning to act in the physical world.
I’m a Member of Technical Staff Intern at Amazon FAR (Frontier AI & Robotics), advised by C. Karen Liu, Guanya Shi, and Haozhi Qi.
Previously, I worked as a research intern at Peking University, JD, and AgiBot, advised by Hao Dong.
I received my master’s (2024) and bachelor’s (2023) in Electrical and Electronic Engineering from Imperial College London, advised by Adam J. Spiers at the Manipulation and Touch Lab.
Away from the lab, you’ll probably find me climbing. My best grades are 7b onsight in sport climbing and V10 (7C+) in indoor bouldering.
Single object-centric bimanual policy for diverse tasks with emergent dexterity
Tech ReportDexterous grasping in cluttered scenes
CoRL 2025 · OralLearning precise in-hand manipulation
ICRA 2025ClutterDexGrasp accepted to CoRL 2025 as an oral presentation.
VF-IHM accepted to ICRA 2025.
Completed my master’s at Imperial College London.
Completed my bachelor’s at Imperial College London.
Object-Centric Bimanual Policy for Emergent Dexterity
A single object-centric policy for emergent pre-grasp manipulation, grasping, regrasping, in-hand manipulation, handover, and bimanual coordination, with zero-shot sim-to-real transfer across tasks and unseen objects.
A Sim-to-Real System for General Dexterous Grasping in Cluttered Scenes
Zero-shot sim-to-real transfer for target-oriented dexterous grasping, across diverse objects and cluttered layouts.
* Equal contribution · Oral, ~5% of accepted papers
For Arbitrary Objects via Diffusion-Based Imitation Learning
Precise in-hand manipulation of arbitrary objects via autonomous play, hindsight goal relabeling of imperfect demos, and sim-real cotraining.
Visual and Physical Real2Sim2Real All-in-One for Robotic Manipulation
Reconstructing scenes and aligning robot-object dynamics in a unified framework for robotic manipulation.
The multi-camera, multi-object perception stack used in SimDuoReal.
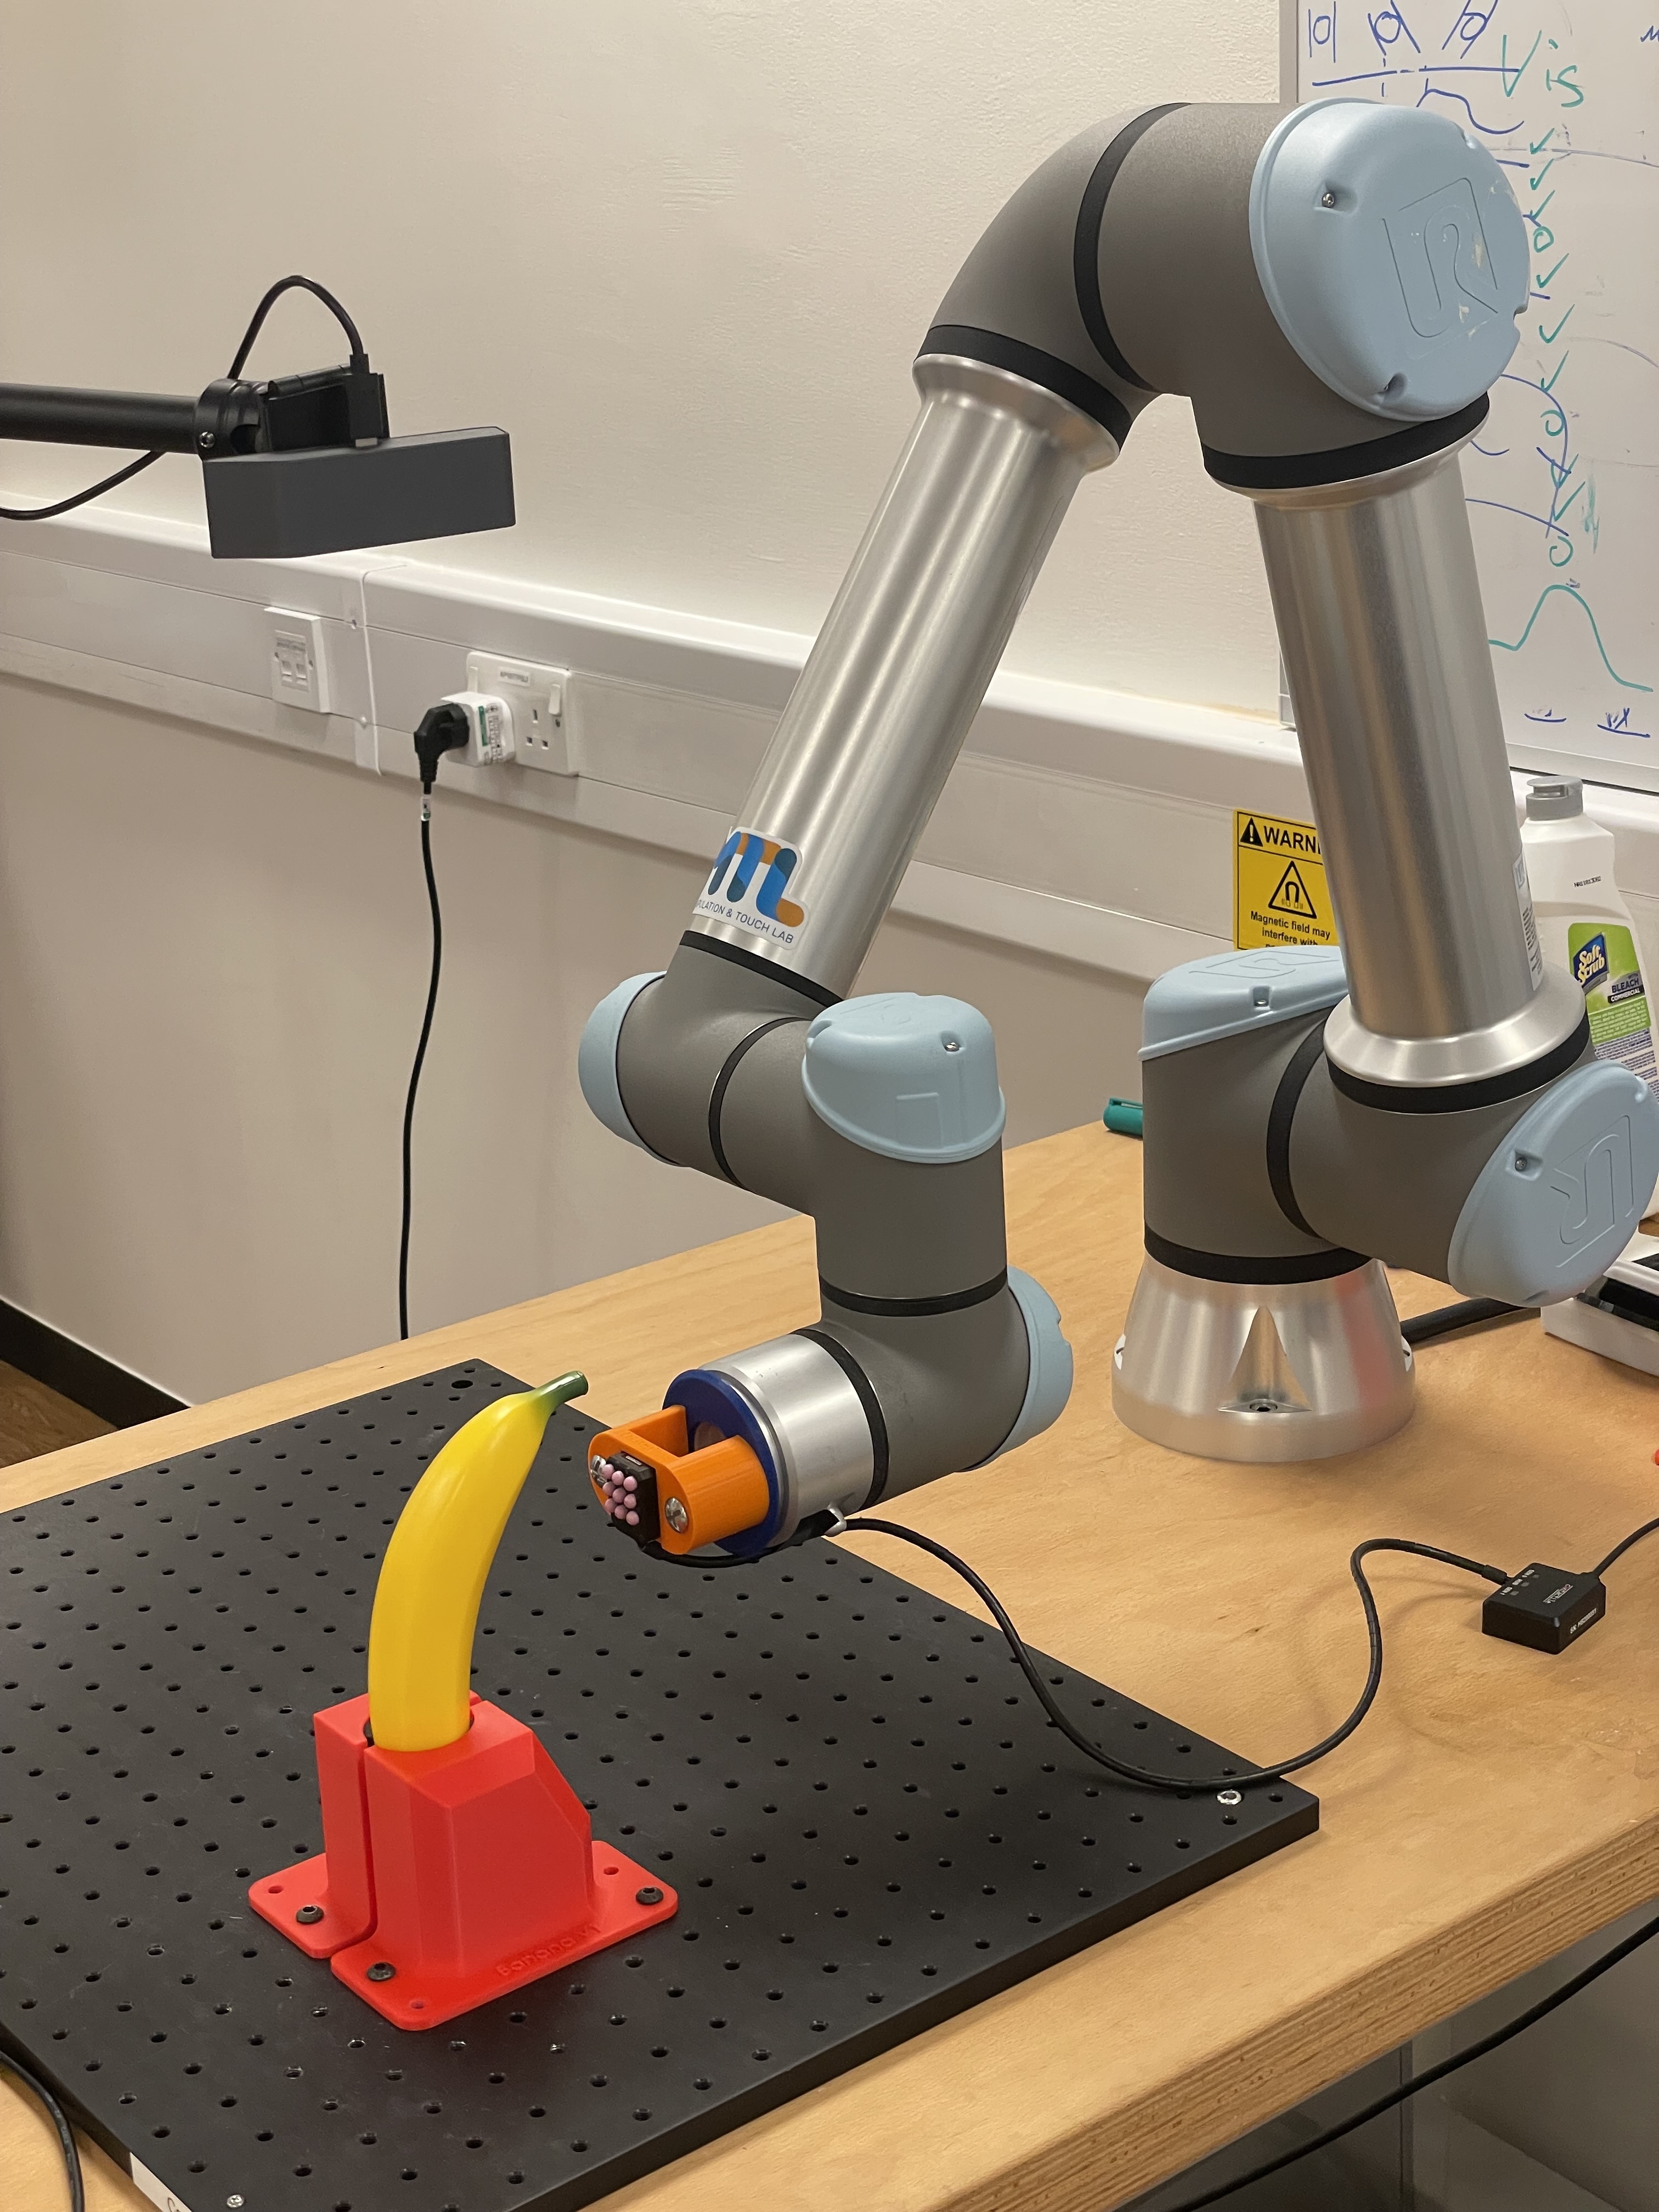
Research Assistant · Manipulation and Touch Lab
Dataset preparation for generalisable learning across different tactile sensors.
Member of Technical Staff Intern
Reviewer · CoRL ’26, RA-L ’26, CoRL ’25, IROS ’25